AUTOMOTIVE / ROBOTICS / CONSTRUCTION / SURVEYING

3D point cloud annotation, delivered fusion-ready.

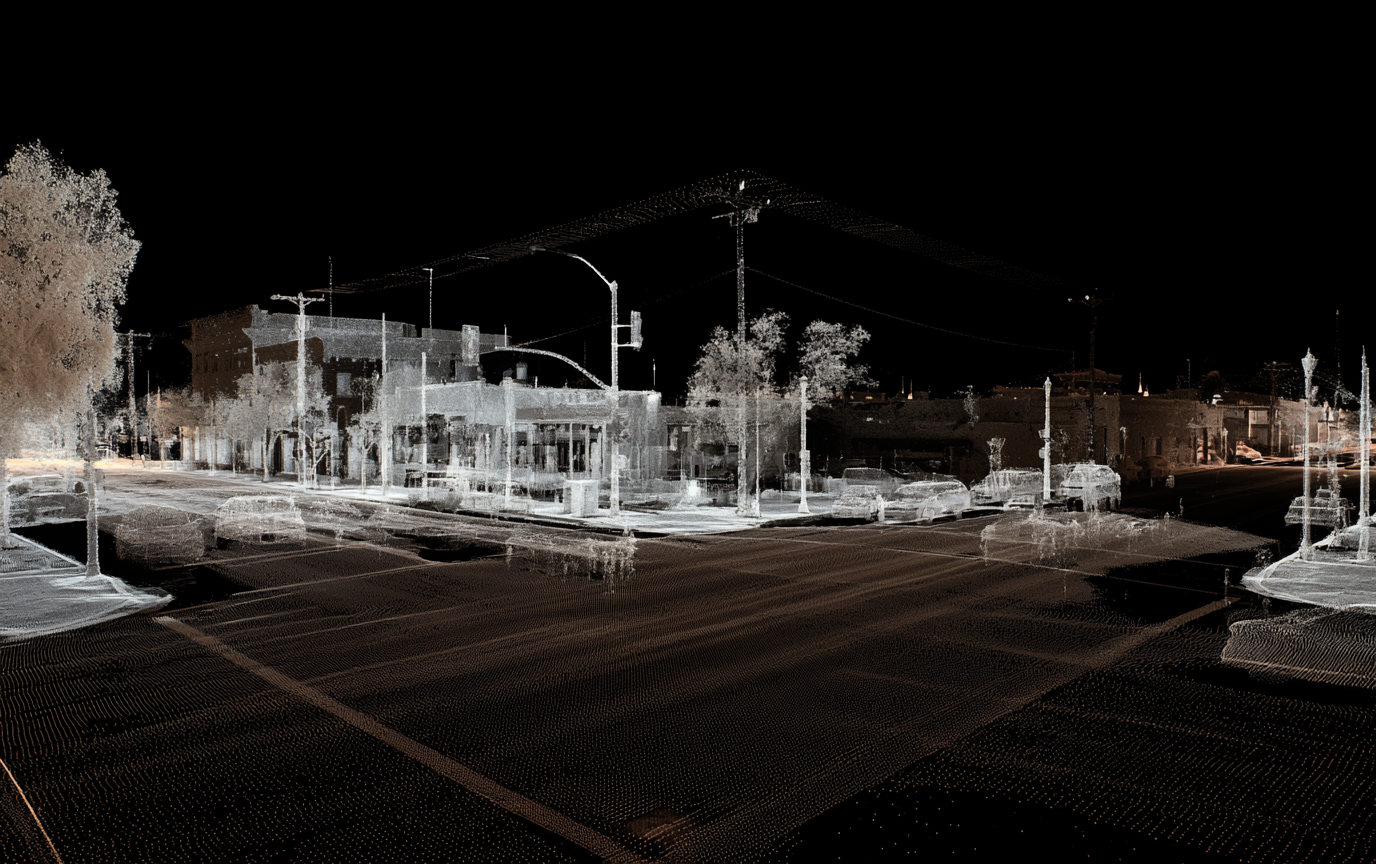
3D cuboid, 9-DoF tracking, semantic per-point, sensor-fusion alignment for LiDAR + camera + radar. EEA processing by default, kappa-gated, calibration checked before annotation.

9-DoF cuboid + tracking EEA residency by default

PROCUREMENT READINESS

Compliance posture for 3D perception training data.

EU AI Act Article 10 enforcement begins 2 December 2027 for standalone Annex III systems and 2 August 2028 for AI embedded in type-approved products such as vehicles. Project-specific data-governance evidence supports automotive engagements.

Included with every delivery

Annotation guideline (versioned)
Calibration verification log
Per-class 3D IoU + BEV mAP report
Tracking continuity report
Records of processing (Article 30)
Signed DPA + sub-processor list

EU AI Act Article 10

Data governance for high-risk AI in vehicles. Annotation provenance, bias-examination notes, ODD coverage documentation, ALKS edge-case taxonomy.

GDPR Articles 7, 28, 30

Per-contributor consent. Processor agreement. Records of processing. 30-day erasure SLA.

EEA processing + Norway jurisdiction

EEA residency by default, Norwegian jurisdiction, and project-specific evidence.

Request the delivery documentation →

We map the delivery documentation to your ODD scope, modality mix, and deployment environment.

PRIMITIVE TYPES

Five 3D annotation primitives.

Which one you procure depends on what your perception stack needs. Ordering cuboids when the stack needs per-point semantics means paying twice.

7-DoF box + class

3D cuboid

7-DoF bounding box (x, y, z, w, h, l, yaw) plus class. Sufficient for most AD object-detection baselines and counting tasks.

Schema
7 floats: x,y,z,w,h,l,yaw + class
Gate
3D IoU >= 0.6 vehicle, >= 0.5 pedestrian
Use case
AD/ADAS perception baseline, counting, basic tracking
x/y/z m w/h/l m yaw rad
Compatible
  • KITTI
  • nuScenes
  • Waymo
yaw, pitch, roll added

9-DoF cuboid

Adds pitch + roll to the 7-DoF box. Captures orientation for rare poses, robotics grasp planning, and motorcycles or off-road cases.

Schema
9 floats: x,y,z,w,h,l,yaw,pitch,roll
Gate
3D IoU >= 0.6 + orientation error < 5°
Use case
Orientation-aware tracking, grasp planning, edge-case poses
x/y/z m w/h/l m y/p/r rad
Compatible
  • nuScenes
  • A2D2
every point labelled

Semantic per-point

Every LiDAR return labelled with a class. Per-point granularity for road surface, vegetation, drivable area, terrain modelling.

Schema
uint8 per point, N classes
Gate
mIoU >= 0.65 over taxonomy
Use case
Road surface, drivable area, terrain DEM
points N classes N
Compatible
  • SemanticKITTI
  • nuScenes-LiDARseg
semantic + instance

Panoptic 3D

Unified per-point class plus per-instance IDs. Single representation for full scene understanding (stuff and things).

Schema
class + instance_id per point
Gate
PQ >= 0.55, RQ >= 0.7
Use case
AD stack training, full scene perception
class id instance id
Compatible
  • Panoptic-nuScenes
  • SemanticKITTI
frame-to-frame continuity

Tracking IDs

Persistent instance IDs across frames. Enables multi-frame perception, prediction, and planning. Identity-switch rate reported in delivery.

Schema
instance_id stable across t
Gate
ID-switches < 2% / km
Use case
Prediction, planning, multi-frame perception
instance id t frame
Compatible
  • nuScenes
  • Waymo
  • KITTI tracking
WHERE LIDAR IS PROCURED

Six verticals, each with its own sensors and ontology.

Different sensors, different ontologies, same delivery contract: EEA processing by default, calibration checked, Article 30 records on delivery.

  • Automotive AD / ADAS

    Cuboid + tracking + multi-modal fusion for perception stacks.

    Typical buyer
    OEM perception team
    Volume and cadence
    Project-specific volume and cadence
    Primary primitive
    9-DoF cuboid + tracking
  • Mobile robotics + AMR

    Warehouse SLAM, delivery autonomy, grasp planning.

    Typical buyer
    Robotics integrator
    Volume and cadence
    Project-specific volume and cadence
    Primary primitive
    cuboid + grasp regions
  • Construction + surveying

    BIM-ready 3D, structural surveying, terrain DEM.

    Typical buyer
    AEC firm or surveyor
    Volume and cadence
    Project-specific density and coverage
    Primary primitive
    semantic per-point + LAS/LAZ
  • Agriculture + drone

    Canopy height, biomass, per-tree segmentation, yield.

    Typical buyer
    Agritech platform
    Volume and cadence
    Seasonal plan defined per project
    Primary primitive
    semantic per-point
  • Infrastructure monitoring

    Rail, pipeline, power line. Change detection, defect localisation.

    Typical buyer
    Asset-operator inspection team
    Volume and cadence
    Periodic plan defined per project
    Primary primitive
    panoptic 3D + change-diff
  • Geospatial mapping

    High-density urban + rural maps for HD positioning.

    Typical buyer
    Mapping / GIS vendor
    Volume and cadence
    Project-specific volume and cadence
    Primary primitive
    semantic per-point

HOW WE LABEL

Every project clears the same six gates.

Calibration checked before annotation. 3D IoU thresholds documented. Multi-frame consistency checked.

Schema + calibration check

Class taxonomy locked with your team. Calibration data (intrinsic, extrinsic, PTP-sync timestamps) checked before annotation begins.

Deliverable: Versioned schema + calibration report

Annotation guideline

Class definitions with ODD scope. Occlusion handling, partial-visibility policy, distance-bucket thresholds for ground truth.

Deliverable: Annotation guideline document

Calibration round

Pilot batch on shared subset. 3D IoU between annotators computed. Camera-LiDAR projection check. Disagreement patterns drive refinement.

Deliverable: Calibration 3D-IoU report

IAA gate

Production starts only when calibration clears the task-specific agreement, geometry, distance, and projection thresholds in the acceptance plan.

Deliverable: Signed record that the gate was cleared

Production with tracker-assist

Multi-frame interpolation between keyframes. Tracker continuity check. Self-hosted CVAT 3D configured per project + proprietary fusion viewer.

Deliverable: Annotated scans + tracking

QA + adjudication + delivery

Per-class 3D IoU. BEV mAP. Tracking continuity. Camera-LiDAR projection consistency. Article 30 records, signed DPA, sub-processor list.

Deliverable: Final delivery + metrics report

Six gates. One trail of evidence. Calibration checked before any annotation.

SCENE COVERAGE

Scene types our 3D pipeline ingests.

Six representative driving scenes, each with the annotation class taxonomy we lock with your team before production. Class counts shift per scene type. Production work runs against your raw scans, multi-frame, with calibration checked.

  1. Urban driving

    4 classes
    • Vehicle
    • pedestrian
    • cyclist
    • lane
  2. Highway

    4 classes
    • Vehicle
    • truck
    • lane
    • sign
  3. Parking

    3 classes
    • Vehicle
    • pedestrian
    • curb
  4. Dense urban

    5 classes
    • Vehicle
    • pedestrian
    • cyclist
    • building
    • sign
  5. Roundabout

    3 classes
    • Vehicle
    • lane
    • curb
  6. Construction zone

    4 classes
    • Vehicle
    • barrier
    • cone
    • sign

Scene types and class taxonomies follow automotive ODD conventions used across public driving datasets (A2D2, nuScenes, KITTI). Production annotation runs on your raw scans, multi-frame, calibration-verified, with Article 30 records on delivery.

PUBLIC BENCHMARK COVERAGE

Benchmark coverage on public datasets.

3D IoU at 0.7 is the threshold autonomous-driving perception teams usually test against. We hold this on the public splits we have published; customer-deployment numbers are reported under NDA.

Most LiDAR public datasets are research-licensed; A2D2 is the notable commercial-clean exception. Production work runs against your own data under your engagement DPA.

Benchmark dataset coverage and procurement license status
Benchmark Split 3D IoU @ 0.7 Distance buckets Tracking continuity License
KITTI / KITTI-360 KITTI format Test in-house: 94% 0-30, 30-60, 60m+ < 1.6% switch / km Research only CC BY-NC-SA
nuScenes nuScenes JSON Val in-house: 92% 0-30, 30-60, 60m+ < 2.1% switch / km Research only Non-commercial
Waymo Open TFRecord, proto Val supported 0-30, 30-50, 50m+ supported Research only Waymo dataset
A2D2 (Audi) PNG + JSON Full in-house: 89% 0-30, 30-60, 60m+ < 2.4% switch / km Commercial OK CC BY-ND 4.0
SemanticKITTI 25 classes/point Val mIoU 0.71 per-point, no buckets n/a (segmentation) Research only CC BY-NC-SA 4.0
Argoverse 2 AV2 SDK Val supported 0-30, 30-100m supported Mixed terms CC BY-NC-SA 4.0

Licence status reflects publicly stated terms. Check per engagement before commercial training use. 'in-house' figures are anonymised customer-deployment results under NDA.

WHAT YOU RECEIVE

Every delivery includes the records your Article 10 file needs.

The records a regulated AD or robotics buyer expects, with every 3D engagement. No upgrade tier, no separate request.

01

Annotation guideline + ODD scope.

Versioned guideline with class definitions, occlusion handling, partial-visibility policy, distance-bucket thresholds. ODD scope documented. Every version preserved for audit.

02

Calibration verification log.

Intrinsic, extrinsic, and PTP-sync timestamp verification before any annotation begins. Calibration drift checks on long sequences. Camera-LiDAR projection consistency report.

03

Per-class 3D IoU + BEV mAP.

Per-class 3D IoU at multiple thresholds. BEV mAP. Per-distance-bucket accuracy (near, mid, far). Orientation error (yaw, pitch, roll). Centre-distance error.

04

Tracking continuity report.

Multi-frame tracking ID continuity. Track switch rate. Per-track length distribution. Identity switches per kilometre or per frame.

05

Records of processing, DPA, and sub-processor list.

Article 30 records of processing, signed Article 28 DPA, lawful-basis documentation, 30-day erasure SLA, and full sub-processor list with Article 28(2) change notifications.

START A PROJECT

Brief us. We reply inside one EU business day.

Short brief now, deeper scoping in the reply.

Looking for work on AI projects? This form is for companies. Apply as a freelancer

Capability lanes (NER, RLHF, etc.), languages, volume, regulatory context.

QUESTIONS

Frequently asked questions

Camera intrinsic + extrinsic parameters, LiDAR-camera extrinsics, PTP-synchronised timestamps. Calibration checked before annotation begins; drift checks on long sequences. Calibration verification log shipped with every delivery.

Yes. LiDAR + camera (most common), LiDAR + camera + radar, LiDAR + IMU + GPS, LiDAR + thermal. Single 3D box drawn in LiDAR and projected to all cameras. Time-synced multi-frame annotation.

Norwegian company, EEA processing by default, EEA-only sourcing on request. 30-day GDPR Article 17 erasure SLA. Norwegian jurisdiction; transfer controls defined per project.

GDPR Article 28 processor obligations, EU AI Act Article 10 data governance, EEA residency by default, DPA-by-default, and project-specific evidence. Records of processing under GDPR Article 30 ship with every delivery.

KITTI format, nuScenes JSON, custom JSON or Protocol Buffers, vendor formats (Ouster, Velodyne, Hesai), PCD, LAS/LAZ for surveying. Customer-owned work product, no reuse rights retained.

GDPR jurisdiction EU AI Act Article 10 EEA operations Consent evidence

Brief us on your 3D perception project.

Reply inside one EU business day. NDA on request. DPA included.

Fusion-ready 3D Calibration checked before annotation

Looking for work on AI projects? This form is for companies. Apply as a freelancer

Or connect on LinkedIn →

Your information is never shared. We respond with the next scoping step.